Povej prijatelju o tem izdelku:
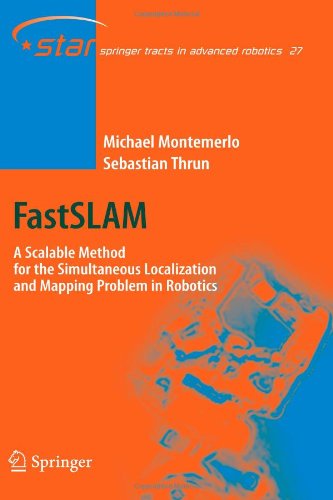
FastSLAM: A Scalable Method for the Simultaneous Localization and Mapping Problem in Robotics - Springer Tracts in Advanced Robotics Michael Montemerlo Softcover reprint of hardcover 1st ed. 2007 edition
Cena
€ 96,99
Naročeno iz oddaljenega skladišča
Predvidena dobava 11. - 19. nov
 Božična darila lahko vrnete do 31. januarja

Prejemajte obvestila o novih izdajah izvajalca Michael Montemerlo
Kaj pravijo naše stranke:

Dodaj na svoj seznam želja iMusic
Na voljo tudi kot:
FastSLAM: A Scalable Method for the Simultaneous Localization and Mapping Problem in Robotics - Springer Tracts in Advanced Robotics
Michael Montemerlo
This monograph describes a new family of algorithms for the simultaneous localization and mapping (SLAM) problem in robotics, called FastSLAM.
120 pages, 9 black & white illustrations, 41 colour illustrations, biography
| Medij | Knjige Paperback Book (Knjiga z mehkimi platnicami in lepljenim hrbtom) |
| Izdano | 18. novembra 2010 |
| ISBN13 | 9783642079788 |
| Založniki | Springer-Verlag Berlin and Heidelberg Gm |
| Strani | 120 |
| Dimenzije | 155 × 235 × 7 mm · 219 g |
| Jezik | Nemščina |




