Povej prijatelju o tem izdelku:
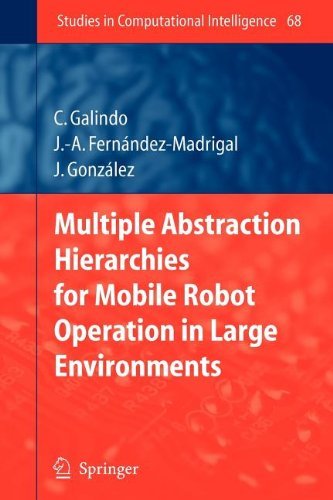
Multiple Abstraction Hierarchies for Mobile Robot Operation in Large Environments - Studies in Computational Intelligence Cipriano Galindo Softcover reprint of hardcover 1st ed. 2007 edition
Cena
€ 96,99
Naročeno iz oddaljenega skladišča
Predvidena dobava 6. - 16. nov
 Božična darila lahko vrnete do 31. januarja

Prejemajte obvestila o novih izdajah izvajalca Cipriano Galindo
Kaj pravijo naše stranke:

Dodaj na svoj seznam želja iMusic
Na voljo tudi kot:
Multiple Abstraction Hierarchies for Mobile Robot Operation in Large Environments - Studies in Computational Intelligence
Cipriano Galindo
This book focuses on the performance of mobile robots through the use of multi-hierarchical symbolic representations of the environment.
To perform deliberative actions, a robot must possess some symbolic representation of its workspace, but representations of real environments can become so large that they must be conveniently arranged to facilitate and, in some cases, make possible their use. Practical solutions tested on real robots, for example a robotic wheelchair, are provided.
178 pages, biography
| Medij | Knjige Paperback Book (Knjiga z mehkimi platnicami in lepljenim hrbtom) |
| Izdano | 30. novembra 2010 |
| ISBN13 | 9783642091759 |
| Založniki | Springer-Verlag Berlin and Heidelberg Gm |
| Strani | 178 |
| Dimenzije | 155 × 235 × 10 mm · 281 g |
| Jezik | Angleščina |




