Povej prijatelju o tem izdelku:
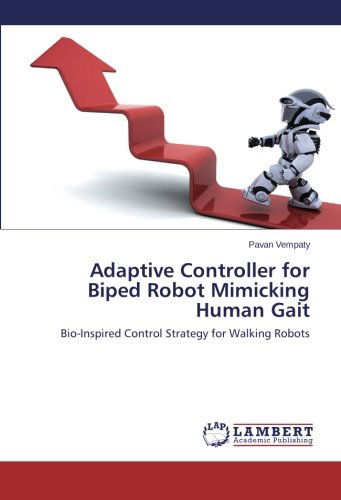
Adaptive Controller for Biped Robot Mimicking Human Gait: Bio-inspired Control Strategy for Walking Robots Pavan Vempaty
Naročeno iz oddaljenega skladišča
 Božična darila lahko vrnete do 31. januarja

Kaj pravijo naše stranke:

Adaptive Controller for Biped Robot Mimicking Human Gait: Bio-inspired Control Strategy for Walking Robots
Pavan Vempaty
This book presents a practical approach to teach the biped humanoid robot to ambulate through human imitation. For this purpose, a human body motion capturing system is developed using tri-axis accelerometers (attached to human legs and torso). The tilt angle patterns information from the human is transformed and estimated to control and teach various ambulatory skills for humanoid robot bipedalism. Lyapunov stability based model reference adaptive controller (MRAC) technique is implemented to address the poorly known actuator dynamic characteristics and unpredictable variations of the biped system. Simulation and experimental results are presented to verify the control scheme of the biped robot mimicking human gait.
| Medij | Knjige Paperback Book (Knjiga z mehkimi platnicami in lepljenim hrbtom) |
| Izdano | 7. marca 2014 |
| ISBN13 | 9783659152795 |
| Založniki | LAP LAMBERT Academic Publishing |
| Strani | 92 |
| Dimenzije | 150 × 6 × 226 mm · 155 g |
| Jezik | Nemščina |
Ogled vseh Pavan Vempaty