Povej prijatelju o tem izdelku:
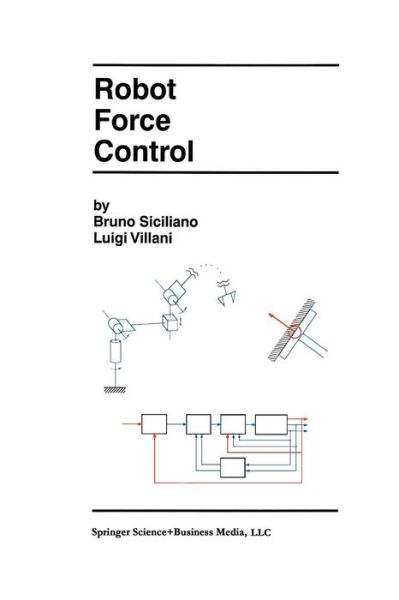
Robot Force Control - The Springer International Series in Engineering and Computer Science Bruno Siciliano 1999 edition
Cena
€ 143,49
Naročeno iz oddaljenega skladišča
Predvidena dobava 28. okt - 5. nov
Prejemajte obvestila o novih izdajah izvajalca Bruno Siciliano
Kaj pravijo naše stranke:

Dodaj na svoj seznam želja iMusic
Na voljo tudi kot:
Robot Force Control - The Springer International Series in Engineering and Computer Science
Bruno Siciliano
In the framework of model-based operational space control, stiffness control and impedance control are presented as the basic strategies for indirect force control; Then, direct force control strategies are presented which are obtained from motion control schemes suitably modified by the closure of an outer force regulation feedback loop.
159 pages, biography
| Medij | Knjige Paperback Book (Knjiga z mehkimi platnicami in lepljenim hrbtom) |
| Izdano | 13. julija 2013 |
| ISBN13 | 9781461369950 |
| Založniki | Springer-Verlag New York Inc. |
| Strani | 146 |
| Dimenzije | 155 × 236 × 13 mm · 240 g |
| Jezik | Angleščina |